Ritwik Joshi
IBM Developer Connect Enterprise Keynote 2018 - 2019 • Pan-India

Project Intu: Humanoid Nao & Watson AI

Pan-India live humanoid demonstrations pairing SoftBank Robotics Nao with IBM Watson AI across Pune, Bengaluru, and Hyderabad.

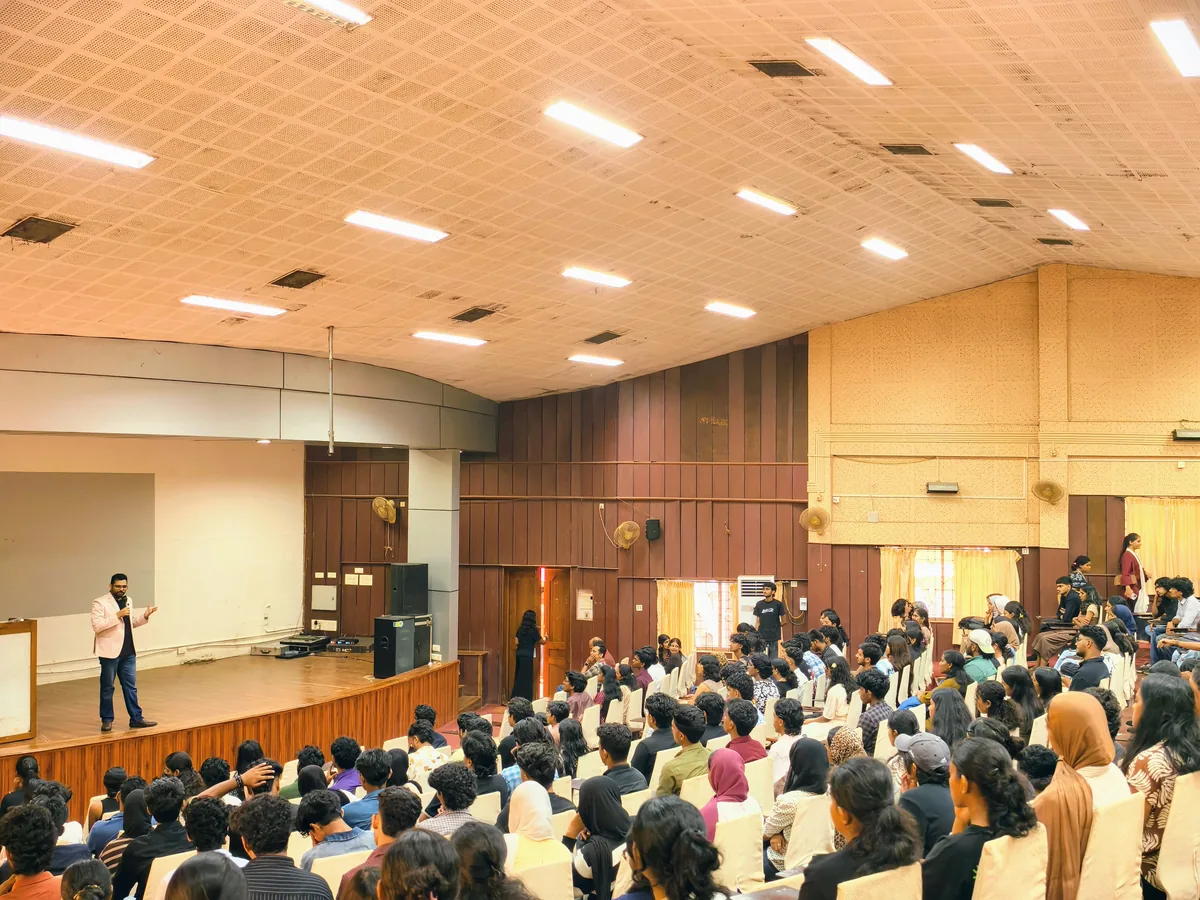
Ritwik Joshi presenting Nao robot powered by IBM Watson at IBM Developer Connect

Organizer / Host

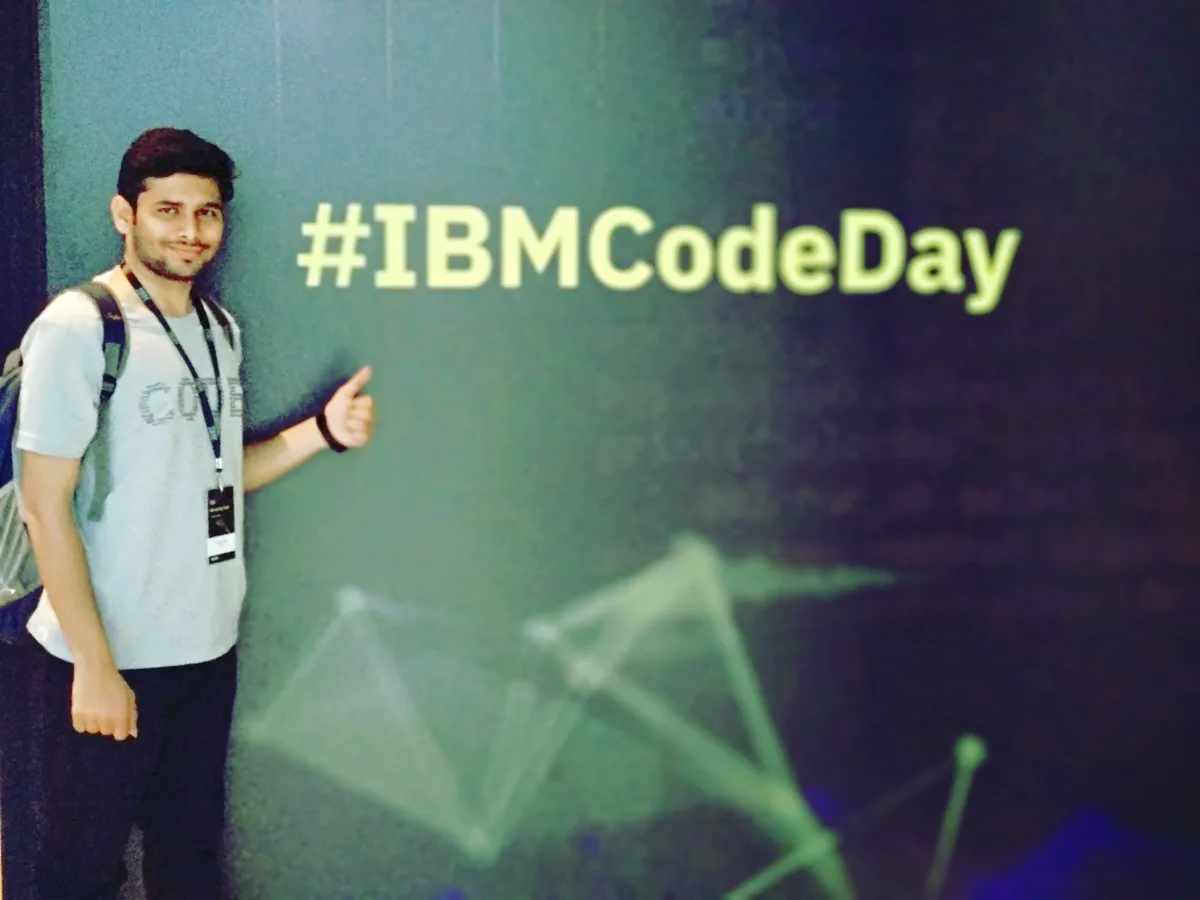
IBM Developer Connect / IBM Code Day

Location & Venue

IBM Developer Connect & IBM Code Day (Pune, Bengaluru, Hyderabad), Pune, Bengaluru & Hyderabad

Timeline & Format

2018 - 2019 • Pan-India • Enterprise Keynote

Audience Cohort

200+ Developers

Executive Session Brief

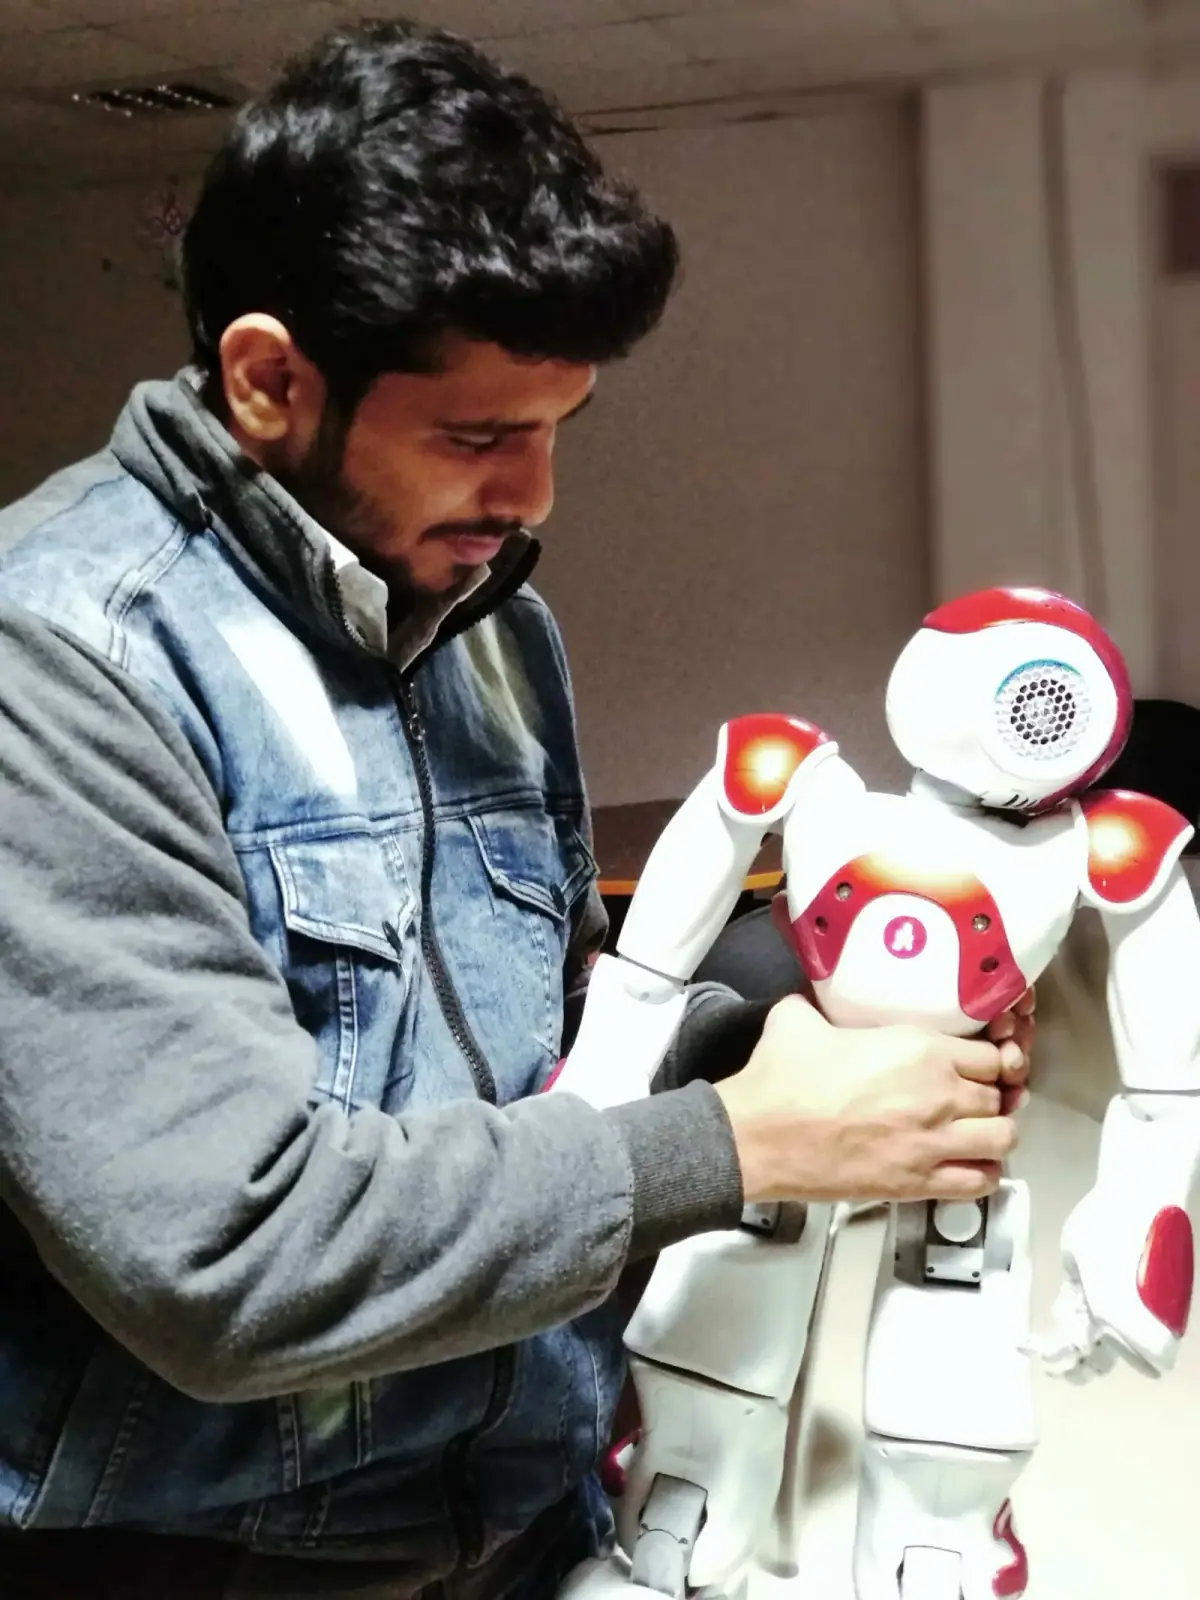
Between 2018 and 2019, Ritwik Joshi delivered live technical demonstrations at IBM Developer Connect (Pune and Bengaluru) and IBM Code Day (Hyderabad) for 200+ software architects and developers. He showcased IBM Project Intu running on the bipedal Nao humanoid robot with real-time conversational perception.

Session Context & Core Thesis

Years before modern multi-modal APIs standardized voice agents, Ritwik brought live embodied intelligence directly onto developer conference stages across Pune, Bengaluru, and Hyderabad. Pairing SoftBank's Nao humanoid robot with IBM Project Intu and Watson services showed architects how cloud cognition translates into physical gesture and speech.

Live robotics demos tolerate zero curated video edits. Onstage sessions covered practical engineering hurdles developers face daily: microphone noise in crowded conference halls, conversational state management, network round-trip latency, and servo synchronization.

Those pan-India enterprise demonstrations laid the multi-year hardware and conversational AI foundation behind Ritwik's current work engineering indigenous humanoid platforms at Yantrarora Innovation (Robosa).
Key Takeaways Delivered

01 • Core Principle

Latency Defines Embodied Trust

A half-second delay on a screen feels minor; on a speaking humanoid robot, slow responses break natural interaction.

02 • Core Principle

Synchronize Speech With Physical Gesture

Embodied systems communicate far more clearly when tone, posture, and micro-expressions align with spoken intent.

03 • Core Principle

Plan Graceful Hardware Fallbacks

Crowded venue acoustics and flaky Wi-Fi require deterministic edge caching and robust state recovery.

04 • Core Principle

Start Early With Real Hardware

Practical sensor and actuation intuition built on Nao in 2018 directly shaped modern Physical AI design choices.

Topics & Frameworks Covered

IBM Project Intu & Watson Nao Humanoid Robotics Natural Language Perception Edge Latency Engineering Embodied Developer Tooling

Stage Photography Gallery (6 Photos)

Click any photo to enlarge

Frequently Asked Questions

What cities hosted Ritwik Joshi's IBM Project Intu Nao demonstrations?

Ritwik Joshi presented live IBM Project Intu and Watson AI demonstrations on the Nao humanoid robot across Pune and Bengaluru (IBM Developer Connect) and Hyderabad (IBM Code Day) in 2018–2019.

What did developers see during the IBM Project Intu sessions?

Over 200 software architects and engineers saw real-time natural language conversation, cloud cognition, and synchronized physical robotics control operating live without canned scripts.

How does this connect to Ritwik's current robotics work?

Experience integrating cognitive AI pipelines onto Nao starting in 2018 evolved into building indigenous, affordable humanoid hardware (Robosa) with 28 full-body DoF and 47 facial micro-actuators.

Related Deep-Dive Guides on This Topic

Enterprise Tech Conferences & Developer Summits

Bring Live Robotics & Physical AI Demos to Your Tech Event

Showcase real embodied AI architecture—never canned slides—at developer conferences across Bengaluru, Pune, Hyderabad, and pan-India.

More Speaking Appearances

View All 18 Events →